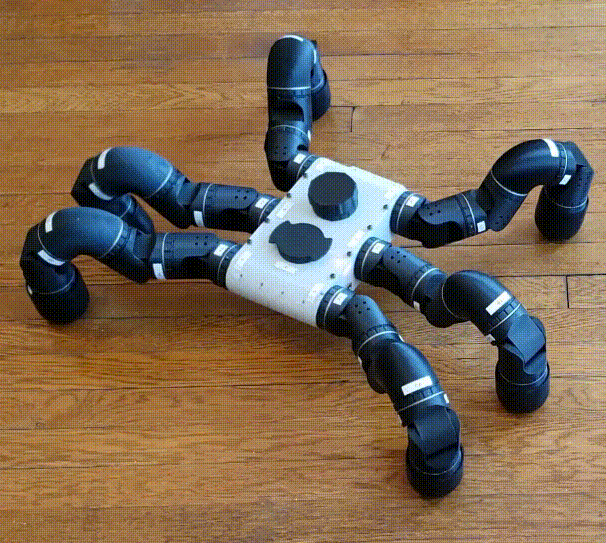
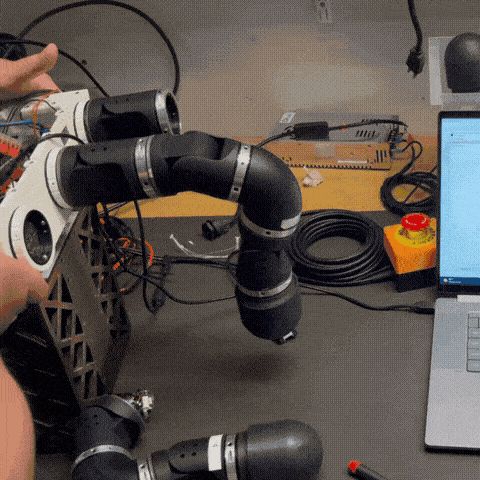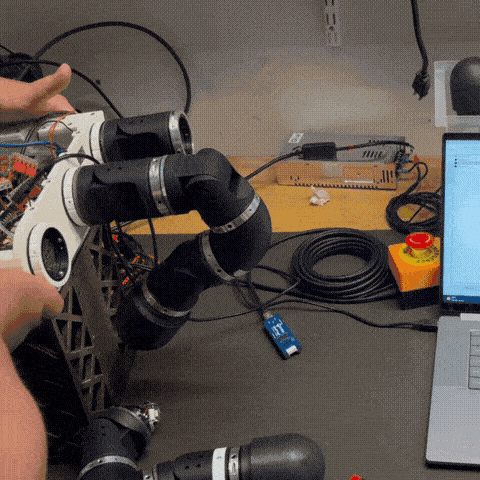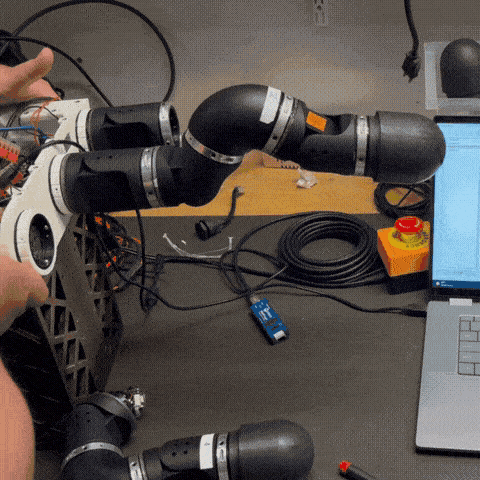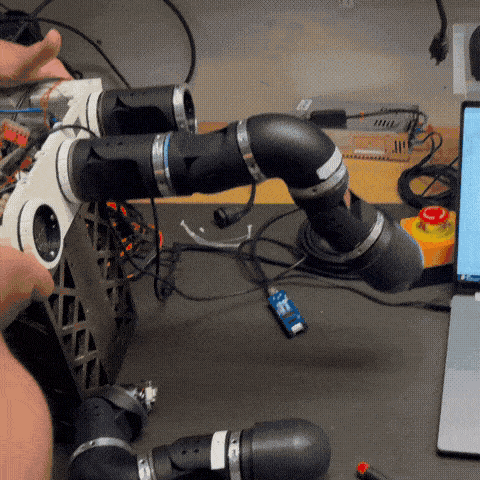
The Eigenbot project at the Biorobotics Lab is a modular robot platform designed for user simplicity. With easily swappable modules, the Eigenbot can adapt to its environment with low barriers to assembly. As an undergraduate research assistant, my work has involved debugging modules and increasing system reliability.
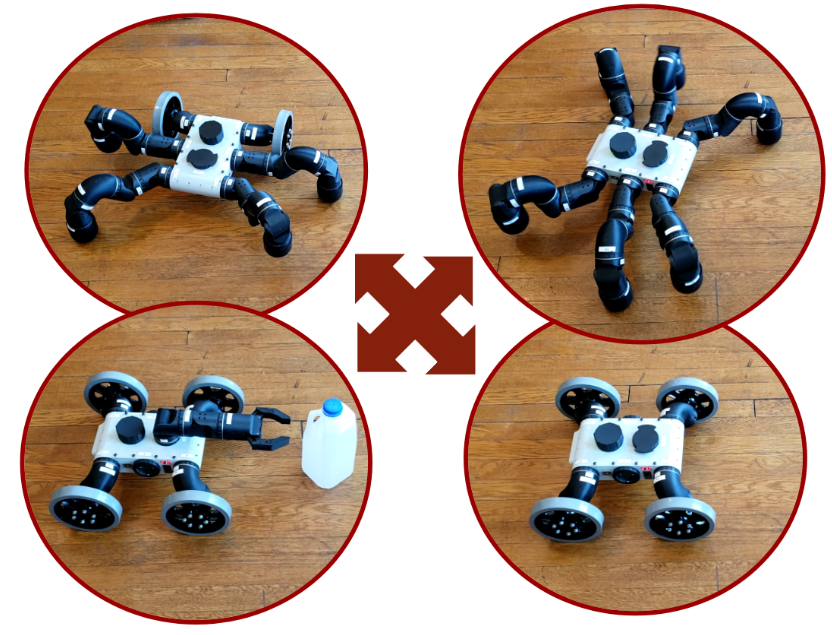
Modular components like the ones on the Eigenbot need to be self-sustaining and system integratable simultaneously. On the Eigenbot, each module contains an Eigenbrain, a custom PCB designed to function as an all-in-one compute, motor driver, and sense board. These boards provide onboard feedback control and motion planning while being designed to operate on their own without the need for large, external computers to run kinematics calculations for them. This creates a uniquely modular ecosystem where individual components can freely swap positions and automatically be recognized for their new position and purpose with little external assistance.
I was honored to be selected for the Summer Undergraduate Research Apprenticeship (SURA) where I worked on debugging and improving the EigenBrains and the modules. Using tools like oscilloscopes and multimeters, I tracked down a series of system-wide communication errors to a single type of faulty spring connector. By replacing these connectors and reflashing old and outdated EigenBrains, I was able to bring the modules back to operational status, improving system reliability in the process.